Finit | Fast & Extensible init for Linux
========================================
[![Travis Status]][Travis] [![Coverity Status]][Coverity Scan]
Table of Contents
-----------------
* [Introduction](#introduction)
* [Features](#features)
* [/etc/finit.conf](#etcfinitconf)
* [/etc/finit.d](#etcfinitd)
* [Bootstrap](#bootstrap)
* [Runlevels](#runlevels)
* [Hooks, Callbacks & Plugins](#hooks-callbacks--plugins)
* [Rebooting and Halting](#rebooting-and-halting)
* [Building](#building)
* [Running](#running)
* [Debugging](#debugging)
* [Origin & References](#origin--references)
Introduction
------------
Init is the first process to run once a UNIX kernel has booted, it
always has PID 1 and is responsible for starting up the rest of the
system. Finit is plugin-based with built in [process supervision][1]
similar to that of D.J. Bernstein's [daemontools][2] and Gerrit Pape's
[runit][3]. The main focus of Finit is on small and embedded GNU/Linux
systems, yet fully functional on standard server and desktop
installations as well.
Traditional [SysV init][4] style systems are scripted. For low-resource
embedded systems this can be quite resource intensive and cause longer
boot times. Finit is optimized to reduce context switches and forking
of processes to provide a very basic bootstrap written entirely in C.
Hence, there is no `/etc/init.d/rcS` script, or similar, but instead a
human-readable `/etc/finit.conf`. This file details what kernel modules
to load, programs to run and daemons to supervise.
The command line arguments given in `/etc/finit.conf` to each service
provide a default. Each service can register callbacks, using plugins,
to override and modify the behavior to suit the current runlevel and
system configuration. For instance, before starting a heavily resource
intensive service like IPsec or OpenVPN, a callback can check if the
outbound interface is up and has an IP address, or just check if the
service is disabled -- much like what a SysV init start script usually
does.
See [TroglOS][9] for an example of how to boot a small embedded system
with Finit.
Features
--------
**Process Supervision**
Start, monitor and restart services if they fail.
**Runlevels**
Runlevels is optional in Finit, but support for [SysV runlevels][5] is
available if needed. All services in runlevel S(1) are started first,
followed by the desired run-time runlevel. Runlevel S can be started in
sequence by using `run [S] cmd`. Changing runlevels at runtime is done
like any other init, e.g. init 4.
**Plugins**
Finit plugins can be either *boot hooks* into different stages of the
boot process or *service callbacks*, or both. A basic set of plugins
that extend and modify the basic behavior are bundled. See examples in
the `plugins/` directory.
Plugin capabilities:
* Service callbacks -- modify service arguments, run/restart/stop
* Task/Run callbacks -- a one-shot commands, executed in sequence
* Hooks -- hook into the boot at predefined points to extend finit
* I/O -- listen to external events and control finit behavior/services
Extensions and functionality not purely related to what an `/sbin/init`
needs to start a system are available as a set of plugins that either
hook into the boot process or respond to various I/O.
/etc/finit.conf
---------------
Contrary to most other script based init alternatives ([SysV init][4],
[upstart][6], [systemd][7], [OpenRC][8], etc.) Finit reads its entire
configuration from `/etc/finit.conf`.
Syntax:
* `check `
Run fsck on a file system before mounting it
* `module `
Load a kernel module, with optional arguments
* `network `
Script or program to bring up networking, with optional arguments
* `runlevel `
N is the runlevel number 1-9, where 6 is reserved for reboot.
Default is 2.
* `run [LVLS] /path/to/cmd ARGS -- Optional description`
One-shot command to run in sequence when entering a runlevel, with
optional arguments and description. This command is guaranteed to be
completed before running the next command.
* `task [LVLS] /path/to/cmd ARGS -- Optional description`
One-shot like 'run', but starts in parallel with the next command
* `service [LVLS] /path/to/daemon ARGS -- Optional description`
Service, or daemon, to be monitored and automatically restarted if it
exits prematurely. Please note that you often need to provide a
--foreground or --no-background argument to most daemons to prevent
them from forking off to the background.
* `runparts `
Call run-parts(8) on a directory other than default ``/etc/finit.d``
* `include `
Include another configuration file, ``/etc/finit.d``, or runparts path
is prepended to file if the file is not found or an absolute path is
not given
* `tty [LVLS] `
Start a getty on the given TTY device, in the given runlevels. When
no tty setting is given in `finit.conf`, or if `/bin/sh` is given as
argument instead of a device path, a single shell is started on the
default console. Useful for really bare-bones systems
See `finit.h` for the `#define GETTY` that is called, along with the
default baud rate.
* `console `
Some embedded systems have a dedicated console port. This command
tells finit to not start getty, but instead print a friendly message
and wait for the user to activate the console with a key press before
starting getty.
When running make install no default `/etc/finit.conf` will
be installed since system requirements differ too much. Try out the
Debian 6.0 example `/usr/share/doc/finit/finit.conf` configuration that
is capable of service monitoring SSH, sysklogd, gdm and a console getty!
/etc/finit.d
------------
At the end of the boot, when networking and all services are up, finit
calls its built-in run-parts(8) on the `/etc/finit.d/` directory, if it
exists. Similar to how the `/ec/rc.local` file works in most other init
daemons, only finit runs a directory of scripts. This replaces the
earlier support for a `/usr/sbin/services.sh` script in the original
finit.
Bootstrap
---------
1. Setup `/dev`
2. Parse `/etc/finit.conf`
3. Load all `.so` plugins
4. Remount/Pivot `/` to get R+W
5. Call 1st level hooks, `HOOK_ROOTFS_UP`
6. Mount `/etc/fstab` and swap, if available
7. Cleanup stale files from `/tmp/*` et al
8. Enable SysV init signals
9. Call 2nd level hooks, `HOOK_BASEFS_UP`
10. Start all 'S' runlevel tasks and services
11. Setup `/etc/sysctl.conf`
12. Setup hostname and loopback
13. Call `network` script, if set in `/etc/finit.conf`
14. Call 3rd level hooks, `HOOK_NETWORK_UP`
15. Switch to active runlevel, as set in `/etc/finit.conf`, default 2.
Here is where the rest of all tasks and services are started.
16. Call 4th level hooks, `HOOK_SVC_UP`
17. Run-parts in `/etc/finit.d`, if any
18. Call 5th level (last) hooks, `HOOK_SYSTEM_UP`
19. Start TTYs defined in `/etc/finit.conf`, or rescue on `/dev/console`
20. Enter main monitor loop
In (10) and (15) tasks and services defined in `/etc/finit.conf` are
started. Remember, all `service` and `task` stanzas are started in
parallel and `run` in sequence, and in the order listed. Hence, to
emulate a SysV `/etc/init.d/rcS` one could write a long file with only
`run` statments.
Notice the five hook points that are called at various point in the
bootstrap process. This is where plugins can extend the boot in any way
they please.
For instance, at `HOOK_BASEFS_UP` a plugin could read an XML file from a
USB stick, convert/copy its contents to the system's `/etc/` directory,
well before all 'S' runlevel tasks are started. This could be used with
system images that are created read-only and all configuration is stored
on external media.
Runlevels
---------
Basic support for [runlevels][5] is included in Finit from v1.8. By
default all services, tasks, run commands and TTYs listed without a set
of runlevels get a default set `[234]` assigned. The default runlevel
after boot is 2.
To specify an allowed set of runlevels for a `service`, `run` command, `task`,
or `tty`, add `[NNN]` to it in your `/etc/finit.conf`, like this:
service [S12345] /sbin/syslogd -n -x -- System log daemon
run [S] /etc/init.d/acpid start -- Starting ACPI Daemon
task [S] /etc/init.d/kbd start -- Preparing console
service [S12345] /sbin/klogd -n -x -- Kernel log daemon
tty [12345] /dev/tty1
tty [2] /dev/tty2
tty [2] /dev/tty3
tty [2] /dev/tty4
tty [2] /dev/tty5
tty [2] /dev/tty6
In this example syslogd is first started, in parallel, and then acpid is
called using a conventional SysV init script. It is called with the run
command, meaning the following task command to start the kbd script is
not called until the acpid init script has fully completed. Then the
keyboard setup script is called in parallel with klogd as a monitored
service.
Again, tasks and services are started in parallel, while run commands
are called in the order listed and subsequent commands are not started
until a run command has completed.
Switching between runlevels can be done by calling init with a single
argument, e.g. init 5 switches to runlevel 5.
Hooks, Callbacks & Plugins
--------------------------
Finit provides only the bare necessities for starting and supervising
processes, with an emphasis on *bare* -- for your convenience it does
however come with support for hooks, service callbacks and plugins that
can used to extend finit with. For your convenience a set of *optional*
plugins are available:
* *alsa-utils.so*: Restore and save ALSA sound settings on
startup/shutdown.
* *bootmisc.so*: Setup necessary files for UTMP, tracks logins at boot.
* *dbus.so*: Setup and start system message bus, D-Bus, at boot.
* *hwclock.so*: Restore and save system clock from/to RTC on
startup/shutdown.
* *initctl.so*: Extends finit with a traditional initctl functionality.
* *resolvconf.so*: Setup necessary files for resolvconf at startup.
* *tty.so*: Watches /dev, using inotify, for new device nodes (TTY's) to
start/stop getty consoles on them on demand.
* *urandom.so*: Setup random seed at startup.
* *x11-common.so*: Setup necessary files for X-Window.
Usually you want to hook into the boot process once, simple hook plugins
like `bootmisc.so` are great for that purpose. They are called at each
hook point in the boot process, useful to insert some pre-bootstrap
mechanisms, like generating configuration files, restoring HW device
state, etc. Available hook points are:
* `HOOK_ROOTFS_UP`: When `finit.conf` has been read and `/` has is
mounted -- very early
* `HOOK_BASEFS_UP`: All of `/etc/fstab` is mounted, swap is available
and default init signals are setup
* `HOOK_NETWORK_UP`: System bootstrap, runlevel S, has completed and
networking is up (`lo` is up and the `network` script has run)
* `HOOK_SVC_UP`: All services in the active runlevel has been launched
* `HOOK_SYSTEM_UP`: All services *and* everything in `/etc/finit.d`
has been launched
* `HOOK_SHUTDOWN`: Called at shutdown/reboot, right before all
services are sent `SIGTERM`
Plugins like `initctl.so` and `tty.so` extend finit by acting on events,
they are called I/O plugins and are called from the finit main loop when
`poll()` detects an event. See the source code for `plugins/*.c` for
more help and ideas.
Callback plugins are called by finit them right before a process is
started, or restarted if it exits. The callback receive a pointer to
the `svc_t` (defined in `svc.h`) of the service, with all command line
parameters free to modify if needed. All the callback needs to do is
respond with one of: `SVC_STOP (0)` tells finit to *not* start the
service, `SVC_START (1)` to start the service, or `SVC_RELOAD (2)` to
have finit signal the process with `SIGHUP`.
Rebooting and Halting
---------------------
Finit handles `SIGUSR1` and `SIGUSR2` for reboot and halt, and listens
to `/dev/initctl` so system reboot and halt commands should also work.
This latter functionality is implemented in the optional `initctl.so`
plugin.
Building
--------
The finit build system does not employ the GNU Configure and Build System,
instead standard makefiles are used. The user is encouraged to make source
code changes, using defines and conditionally building plugins instead to
alter the behavior of finit.
The following environment variables are checked by the makefiles and control
what is built and where resulting binaries are installed.
* `ROOTDIR=`: Top directory for building complete system, used in pretty
printing.
* `VERSION=`: Defaults to the currently released version of finit,
e.g., 1.3 but can be overridden by packagers using this variable to
add a suffix or completely alter the version.
* `CFLAGS=`: Default `CFLAGS` are inherited from the environment.
* `CPPFLAGS=`: Default `CPPFLAGS` are inherited from the environment.
* `LDFLAGS=`: Default `LDFLAGS` are inherited from the environment.
* `LDLIBS=`: Default `LIBLIBS` are inherited from the environment.
* `prefix=`: Base prefix path for all files, except `sbinbdir` and
`sysconfdir`. Used in concert with the `DESTDIR` variable.
Defaults to `/usr`.
* `sbindir=`: Path to where resulting binaries should install to. Used
in concert with the `DESTDIR` variable.
Defaults to `/sbin`.
* `sysconfdir=`: Path to where finit configuration files should install
to. Used in concert with the `DESTDIR` variable.
Defaults to `/etc`, but is currently unused.
* `PLUGINS=`: List of stock finit plugins to build and install.
* `plugindir=`: Absolute path to where finit should look for dynamically
loadable plugins at runtime. At installation prepended by `DESTDIR`
and `prefix`.
Defaults to `/lib/finit/plugins`.
* `DESTDIR=`: Used by packagers and distributions when building a
relocatable bundle of files. Always prepended to the `prefix`
destination directory.
**Example**
First, unpack the archive:
$ tar xfJ finit-1.3.tar.xz; cd finit-1.3/
Then build and install:
$ PLUGINS="initctl.so hwclock.so" DESTDIR=/tmp/finit make install
CC finit.o
CC conf.o
CC helpers.o
CC sig.o
CC svc.o
CC plugin.o
CC strlcpy.o
LINK finit
CC plugins/initctl.o
PLUGIN plugins/initctl.so
CC plugins/hwclock.o
PLUGIN plugins/hwclock.so
INSTALL /tmp/finit/sbin/finit
INSTALL /tmp/finit/lib/finit/plugins/initctl.so
INSTALL /tmp/finit/lib/finit/plugins/hwclock.so
In this example the [finit-1.3.tar.xz][10] archive is unpacked to the
user's home directory, built and installed to a temporary staging
directory. The environment variables `DESTDIR` and `PLUGINS` are
changed to suit this particular build.
Running
-------
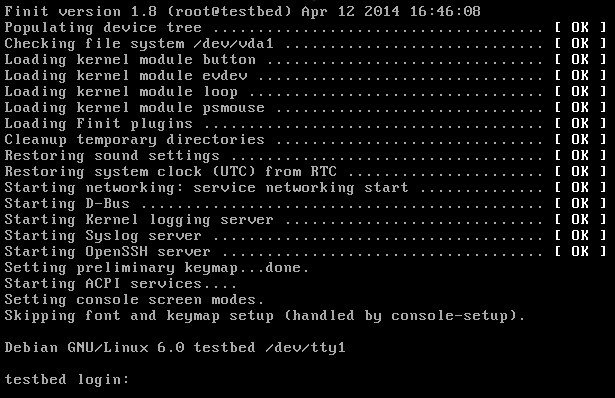
The default install does not setup finit as the system default
`/sbin/init`, neither does it setup an initial `/etc/finit.conf`.
It is assumed that users of finit are competent enough to either setup
finit as their default `/sbin/init` or alter their respective Grub,
LOADLIN, LILO, U-Boot/Barebox or RedBoot boot loader configuration to
give the kernel the following extra command line:
init=/sbin/finit
Debugging
---------
Add `finit_debug`, or `--debug`, to the kernel command line to
enable trace messages. A console getty is always started, see the file
`finit.h` for more useful compile-time tweaks:
init=/sbin/finit --debug
Origin & References
-------------------
This is the continuation of the [original finit] by [Claudio Matsuoka],
which in turn was reverse engineered from syscalls of the
[EeePC fastinit] -- "gaps filled with frog DNA ..."
Finit is currently being developed and maintained by [Joachim Nilsson]
at [GitHub]. Please file bug reports, clone it, or send pull requests
for bug fixes and proposed extensions.
[1]: https://en.wikipedia.org/wiki/Process_supervision
[2]: http://cr.yp.to/daemontools.html
[3]: http://smarden.org/runit/
[4]: http://en.wikipedia.org/wiki/Init
[5]: http://en.wikipedia.org/wiki/Runlevel
[6]: http://upstart.ubuntu.com/
[7]: http://www.freedesktop.org/wiki/Software/systemd/
[8]: http://www.gentoo.org/proj/en/base/openrc/
[9]: https://github.com/troglobit/troglos
[10]: ftp://troglobit.com/finit/finit-1.3.tar.xz
[original finit]: http://helllabs.org/finit/
[EeePC fastinit]: http://wiki.eeeuser.com/boot_process:the_boot_process
[Claudio Matsuoka]: https://github.com/cmatsuoka
[Joachim Nilsson]: http://troglobit.com
[GitHub]: https://github.com/troglobit/finit
[Travis]: https://travis-ci.org/troglobit/finit
[Travis Status]: https://travis-ci.org/troglobit/finit.png?branch=master
[Coverity Scan]: https://scan.coverity.com/projects/3545
[Coverity Status]: https://scan.coverity.com/projects/3545/badge.svg